Stereo image acquisition
In order to address the loss of depth information, given 2 images of a 3D scene and correspondence in points the depth of a point can be recovered using triangulation.
so given the following model:
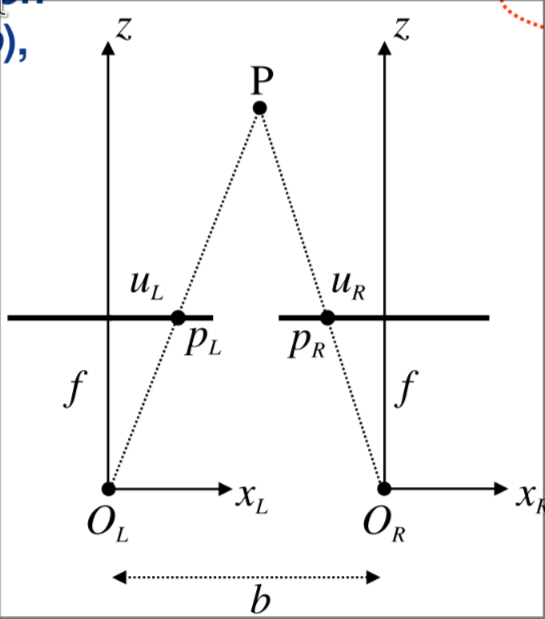
The relation between the 2 images is only an horizontal translation
$$ x_{l} - x_{r} = b $$ $$ y_{l} = y_{r}= y $$ $$ z_{l} = z_{r} = z $$
The perspective projection model the relation between image points and 3D ones can be described as follows:
$$ u_{L} = x_{L}\frac{f}{z} $$ $$ u_{R} = x_{R}\frac{f}{z} $$ computing the difference:
$$ u_{L} – u_{R} = b*\frac{f}{z} $$
It’s true to say that $u_{L} – u_{R}$ can be computed from image measurements
$$ u_{L} – u_{R} = d $$
where $d$ is called disparity. than $z$ can be computed
$$ d = b*\frac{f}{z} \Rightarrow z = b*\frac{f}{d} $$
The problem of finding correspondences
In order to apply this model the correspondences between the points of the 2 images need to be computed, this is not an easy task nether computationally or conceptually, also the models relays on the 2 images being horizontally aligned, and to obtained this some computation is needed.
fortunately, the search space for correspondences is always 1 dimensional as 2 points share always the same $y$ coordinate. To address the horizontal alignment problem a homography called rectification is used on the images to warp them and obtain something horizontally aligned.