Generalized hugh transform
The Generalized Hough transform (GHT) is a generalization aimed to apply HT to non analytical shapes.
Ght with local invariant features
The most popular computer vision pipeline relies on combining GHT with local invariant features such as the SIFT DESCRIPTOR. In this pipeline Local invariant features are used instead of edges.
Ght: offline phase
Detect keypoints (e.g. DOG) and compute descriptors (e.g. SIFT) in the model image:
$$ F = {F_1,F_2,…,F_n} $$ $$ F_i = (P_i,D_i,\phi_i,S_i) $$
Choose a reference point (eg the barycentre)
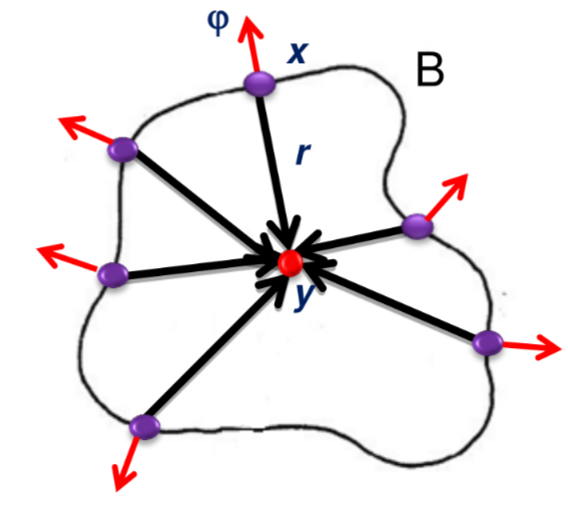
$$ P_C = \frac{1}{N}\sum_{i=1}^{N}P_i $$ Compute the joining vectors between the features and the reference point:
$$ \forall F_i \in F \rightarrow V_i= P_C -P_i $$
The Star Model consist of the features and their joining vectors (no need of the R Table):
$$ F_i = (P_i,D_i,\phi_i,S_i,V_i) $$
Ght: online phase
Detect keypoints on the target image and compute descriptors :
$$ \overset{\sim}F = {\overset{\sim}F_1,\overset{\sim}F_2,…,\overset{\sim}F_n} $$ $$ \overset{\sim}F_i = (\overset{\sim}P_i,\overset{\sim}D_i,\overset{\sim}\phi_i,\overset{\sim}S_i) $$
Match descriptor between target and model image
$$ \forall \overset{\sim}F_i \in \overset{\sim}F \rightarrow \overset{\sim}D_j = D_j $$
for each keypoint on the target image that matches his descriptor with a keypoint in the model image compute the reference point and cast a vote in the accumulator array
$$ \overset{\sim}P_{C_j} = \overset{\sim}P_j + \overset{\sim}V_j $$ $$ A[\overset{\sim}P_{C_j} ] ++ $$
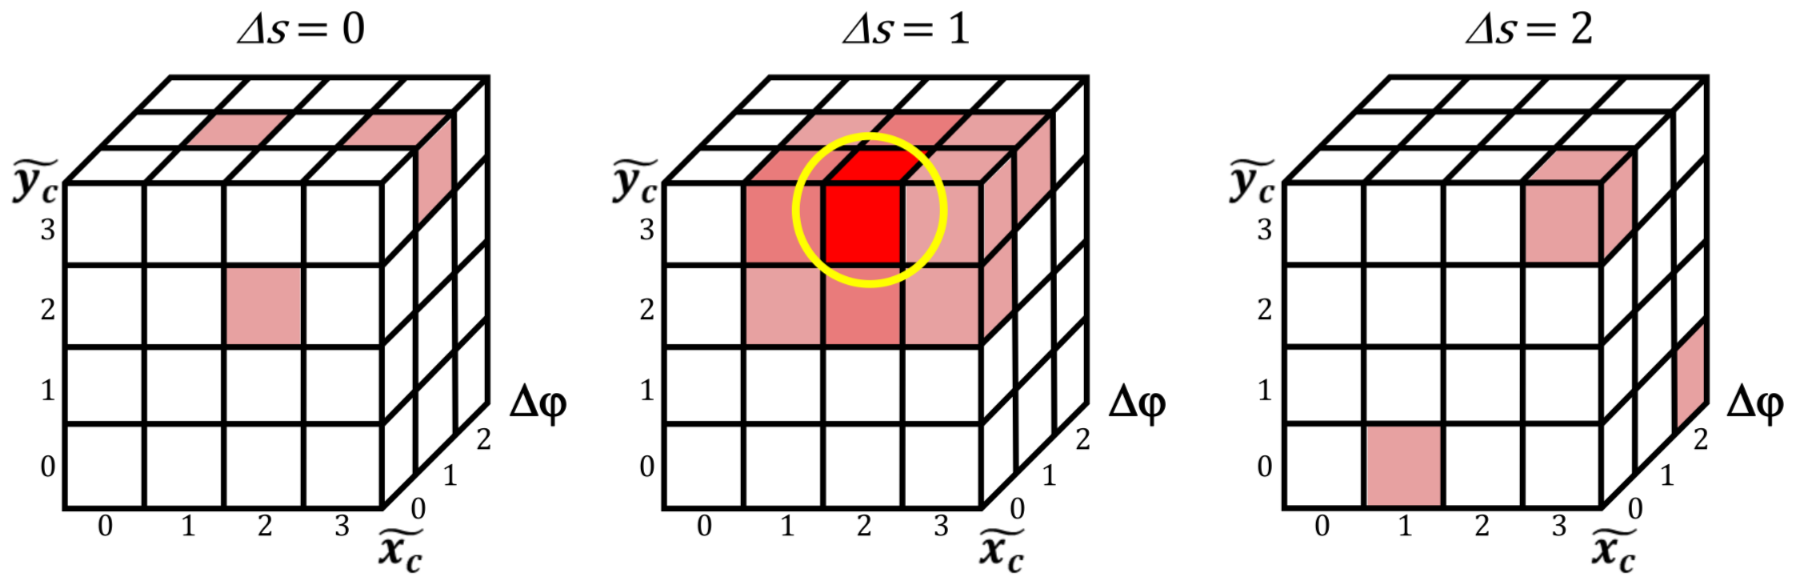
2d accumulator array issues
A 2D accumulator array is not sufficient to account for rotation and scale, the solution is to use a 4D accumulator array in order to account for scale and rotation